An interactive system that translates finger movements into physical motion, connecting computer vision and servo motors.
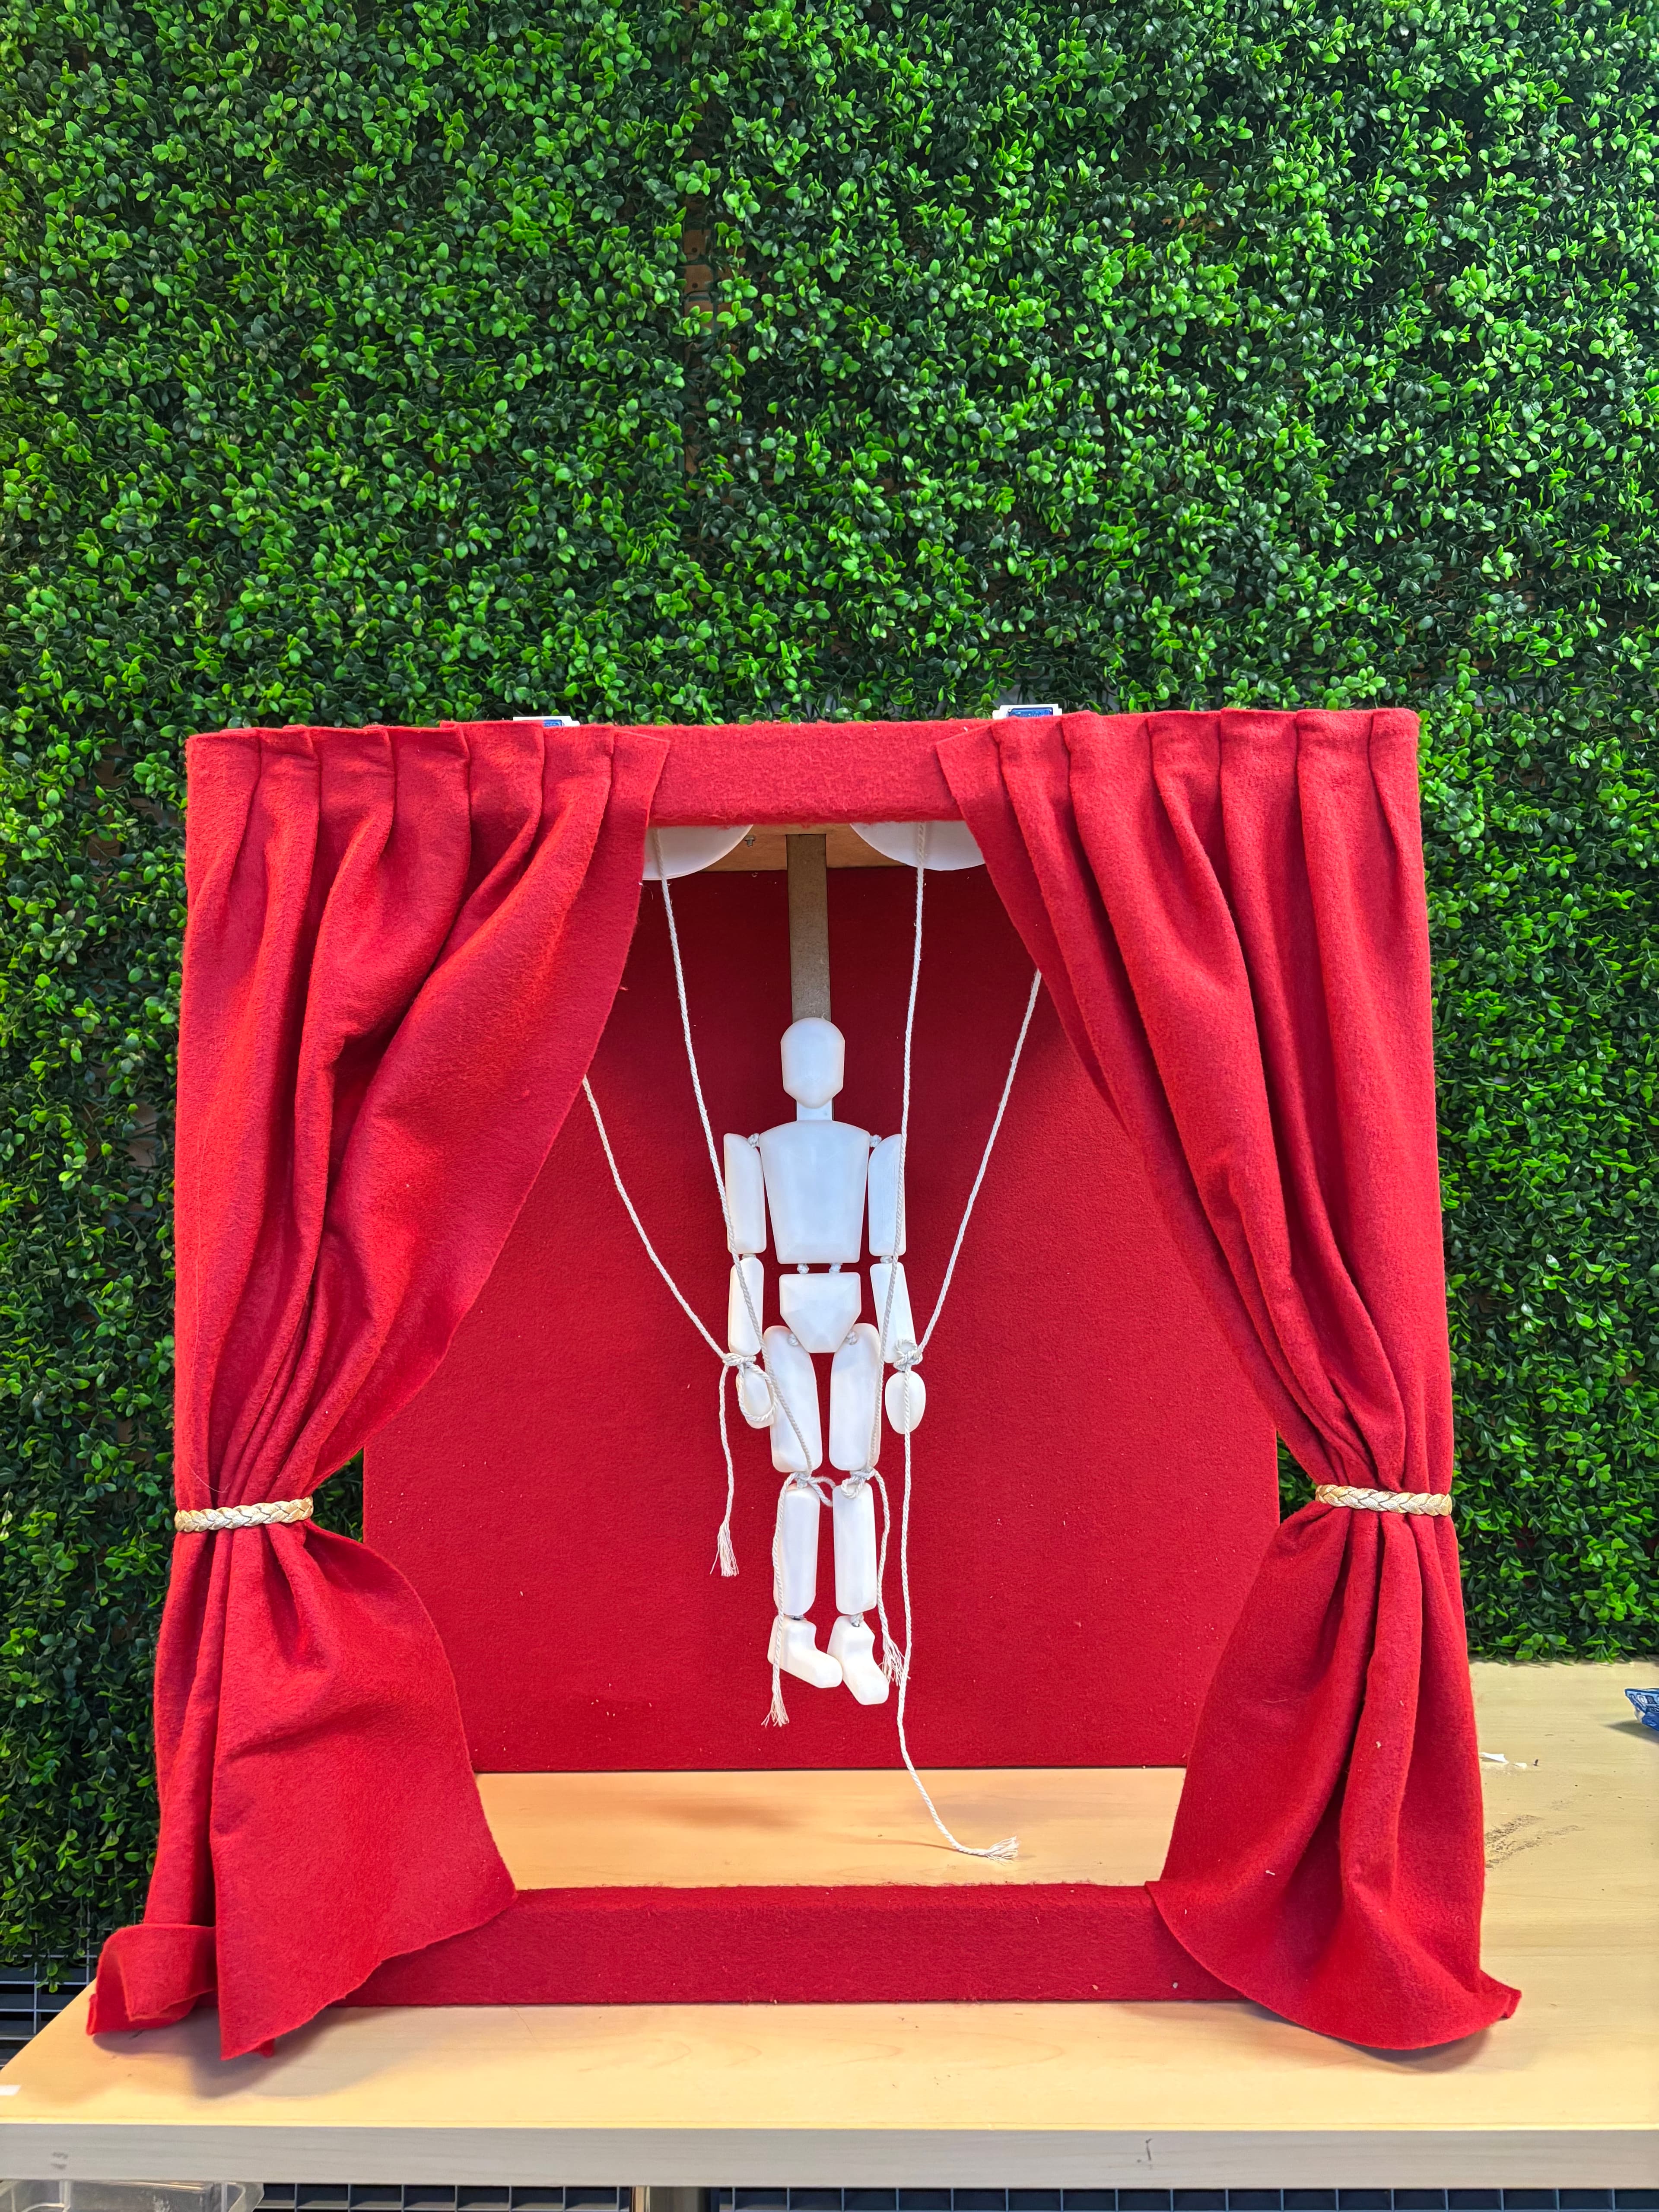
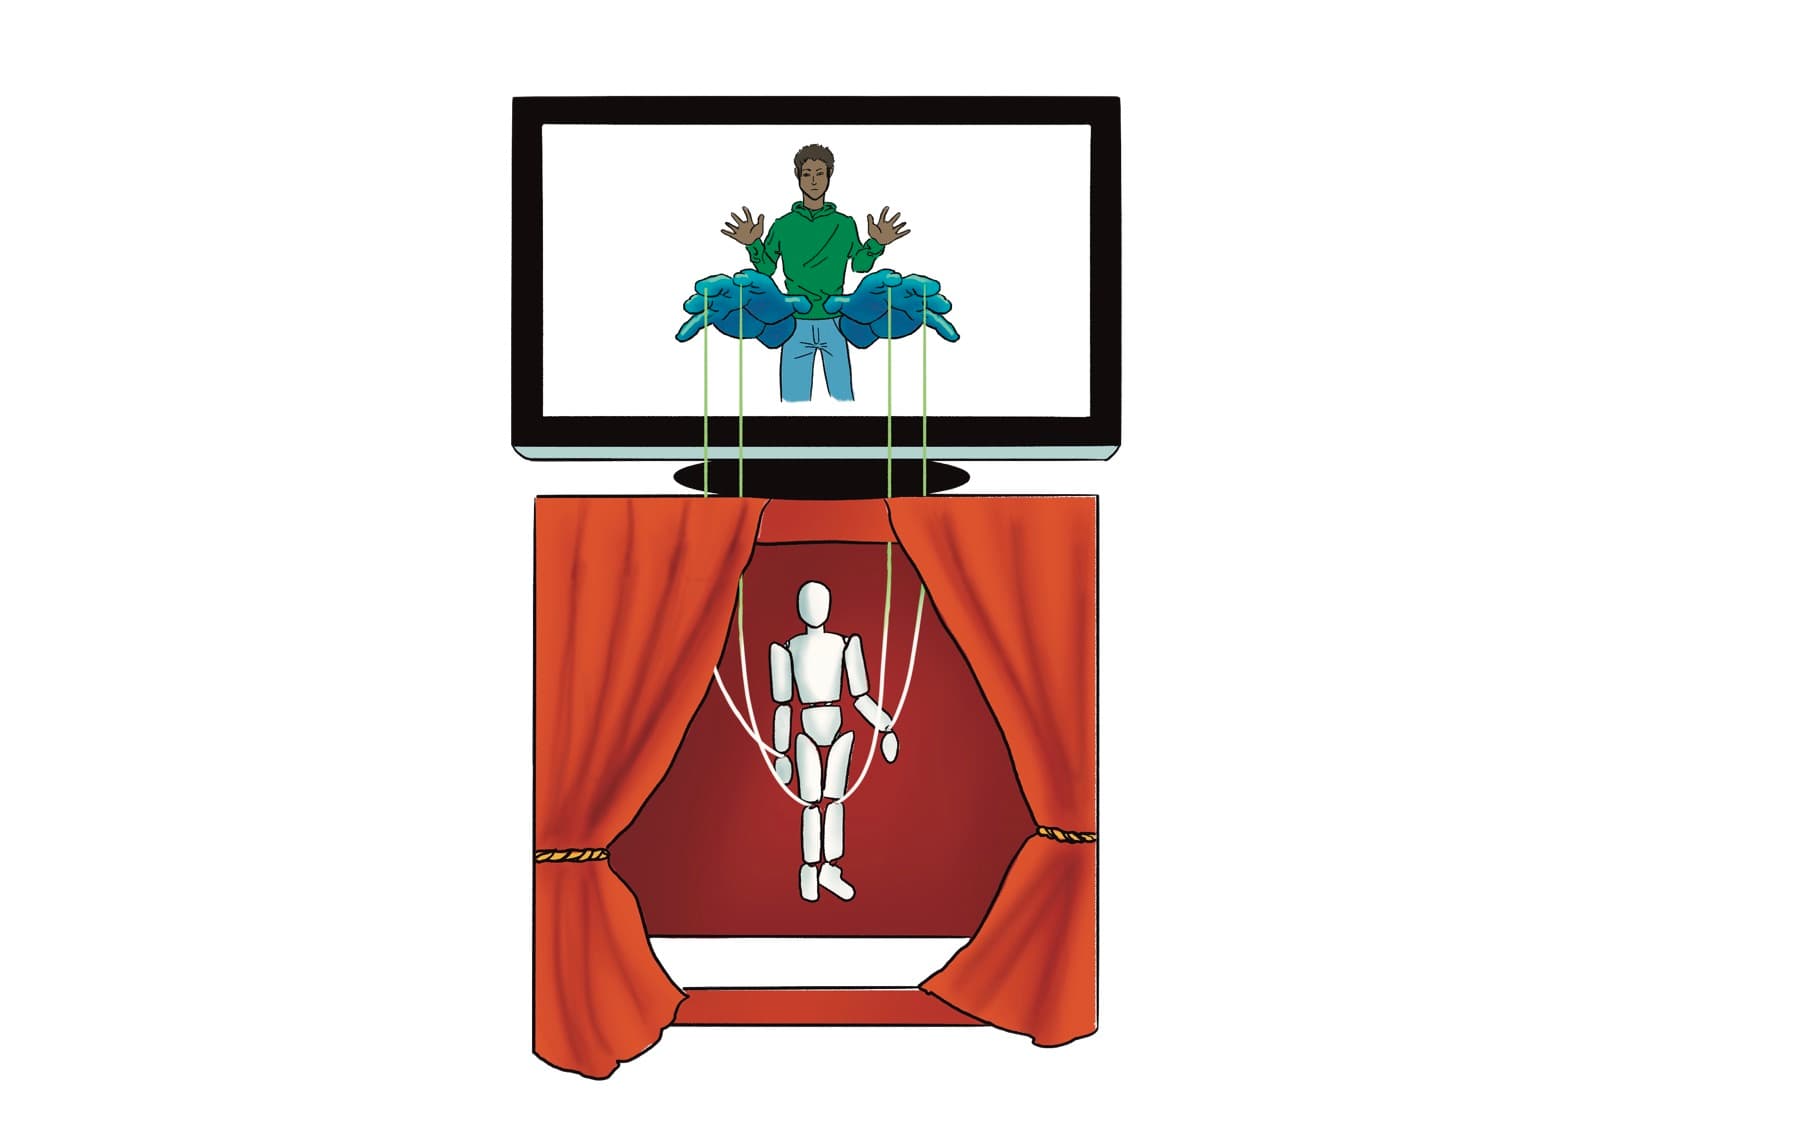
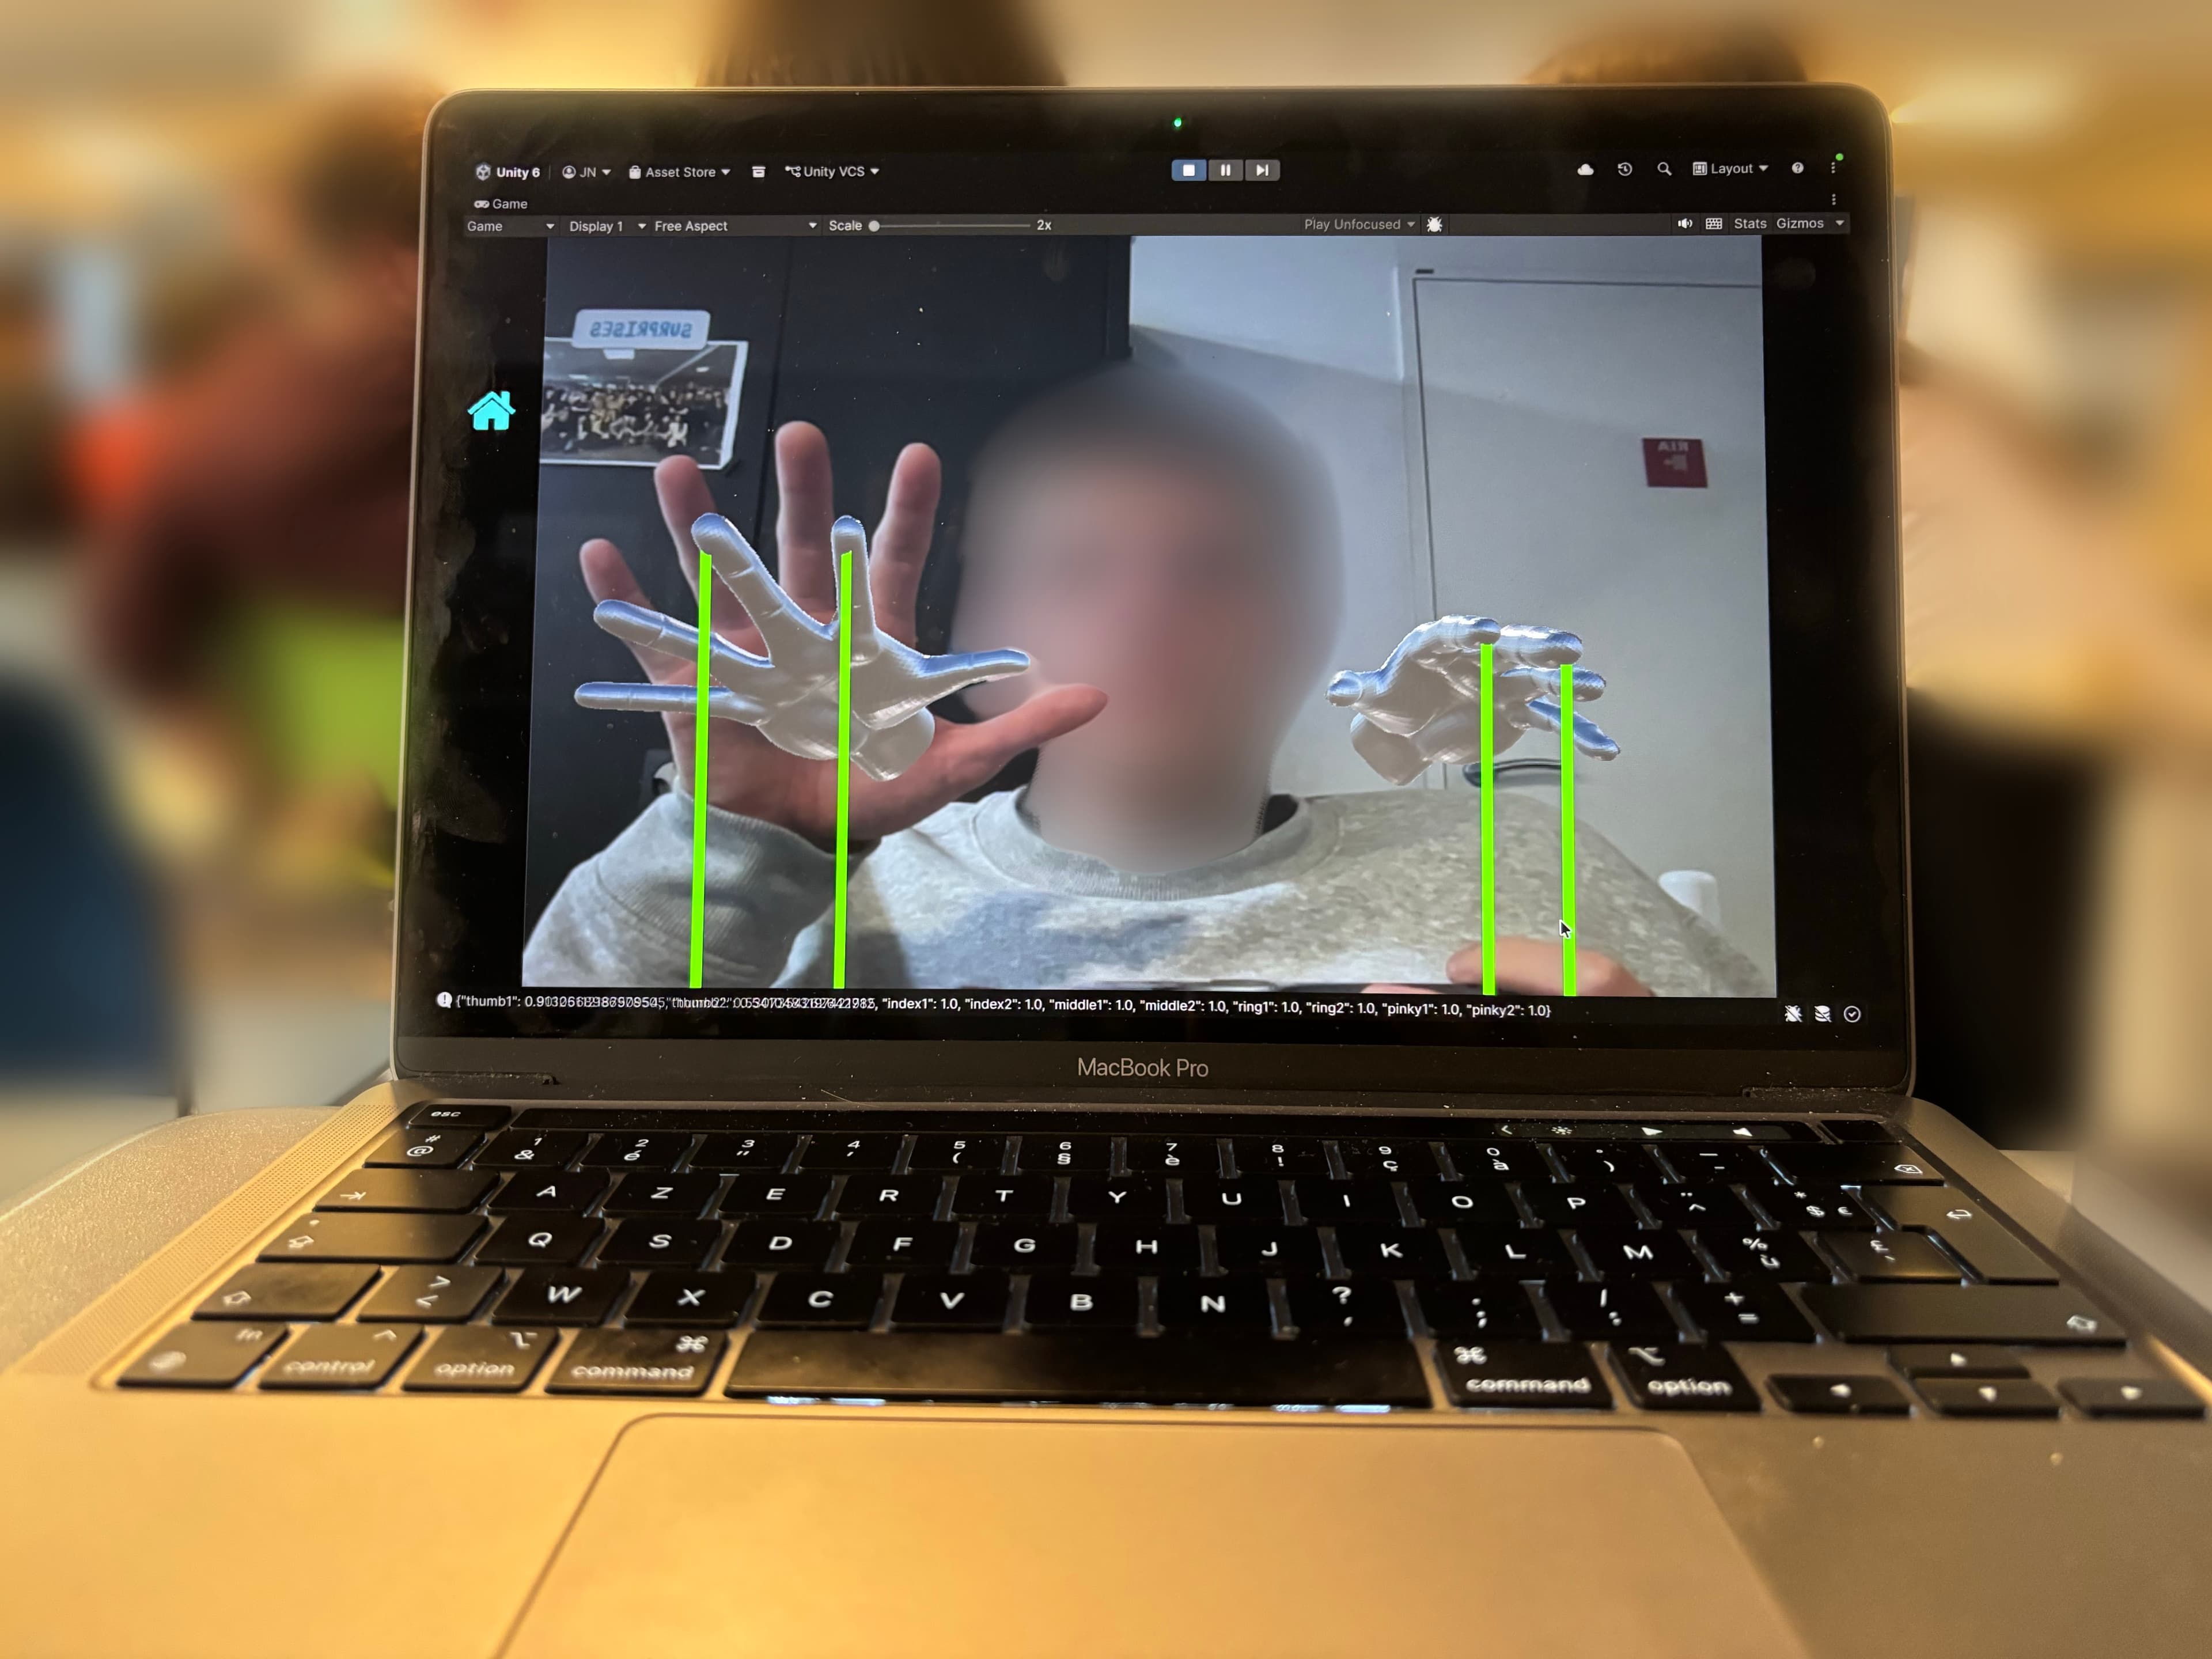
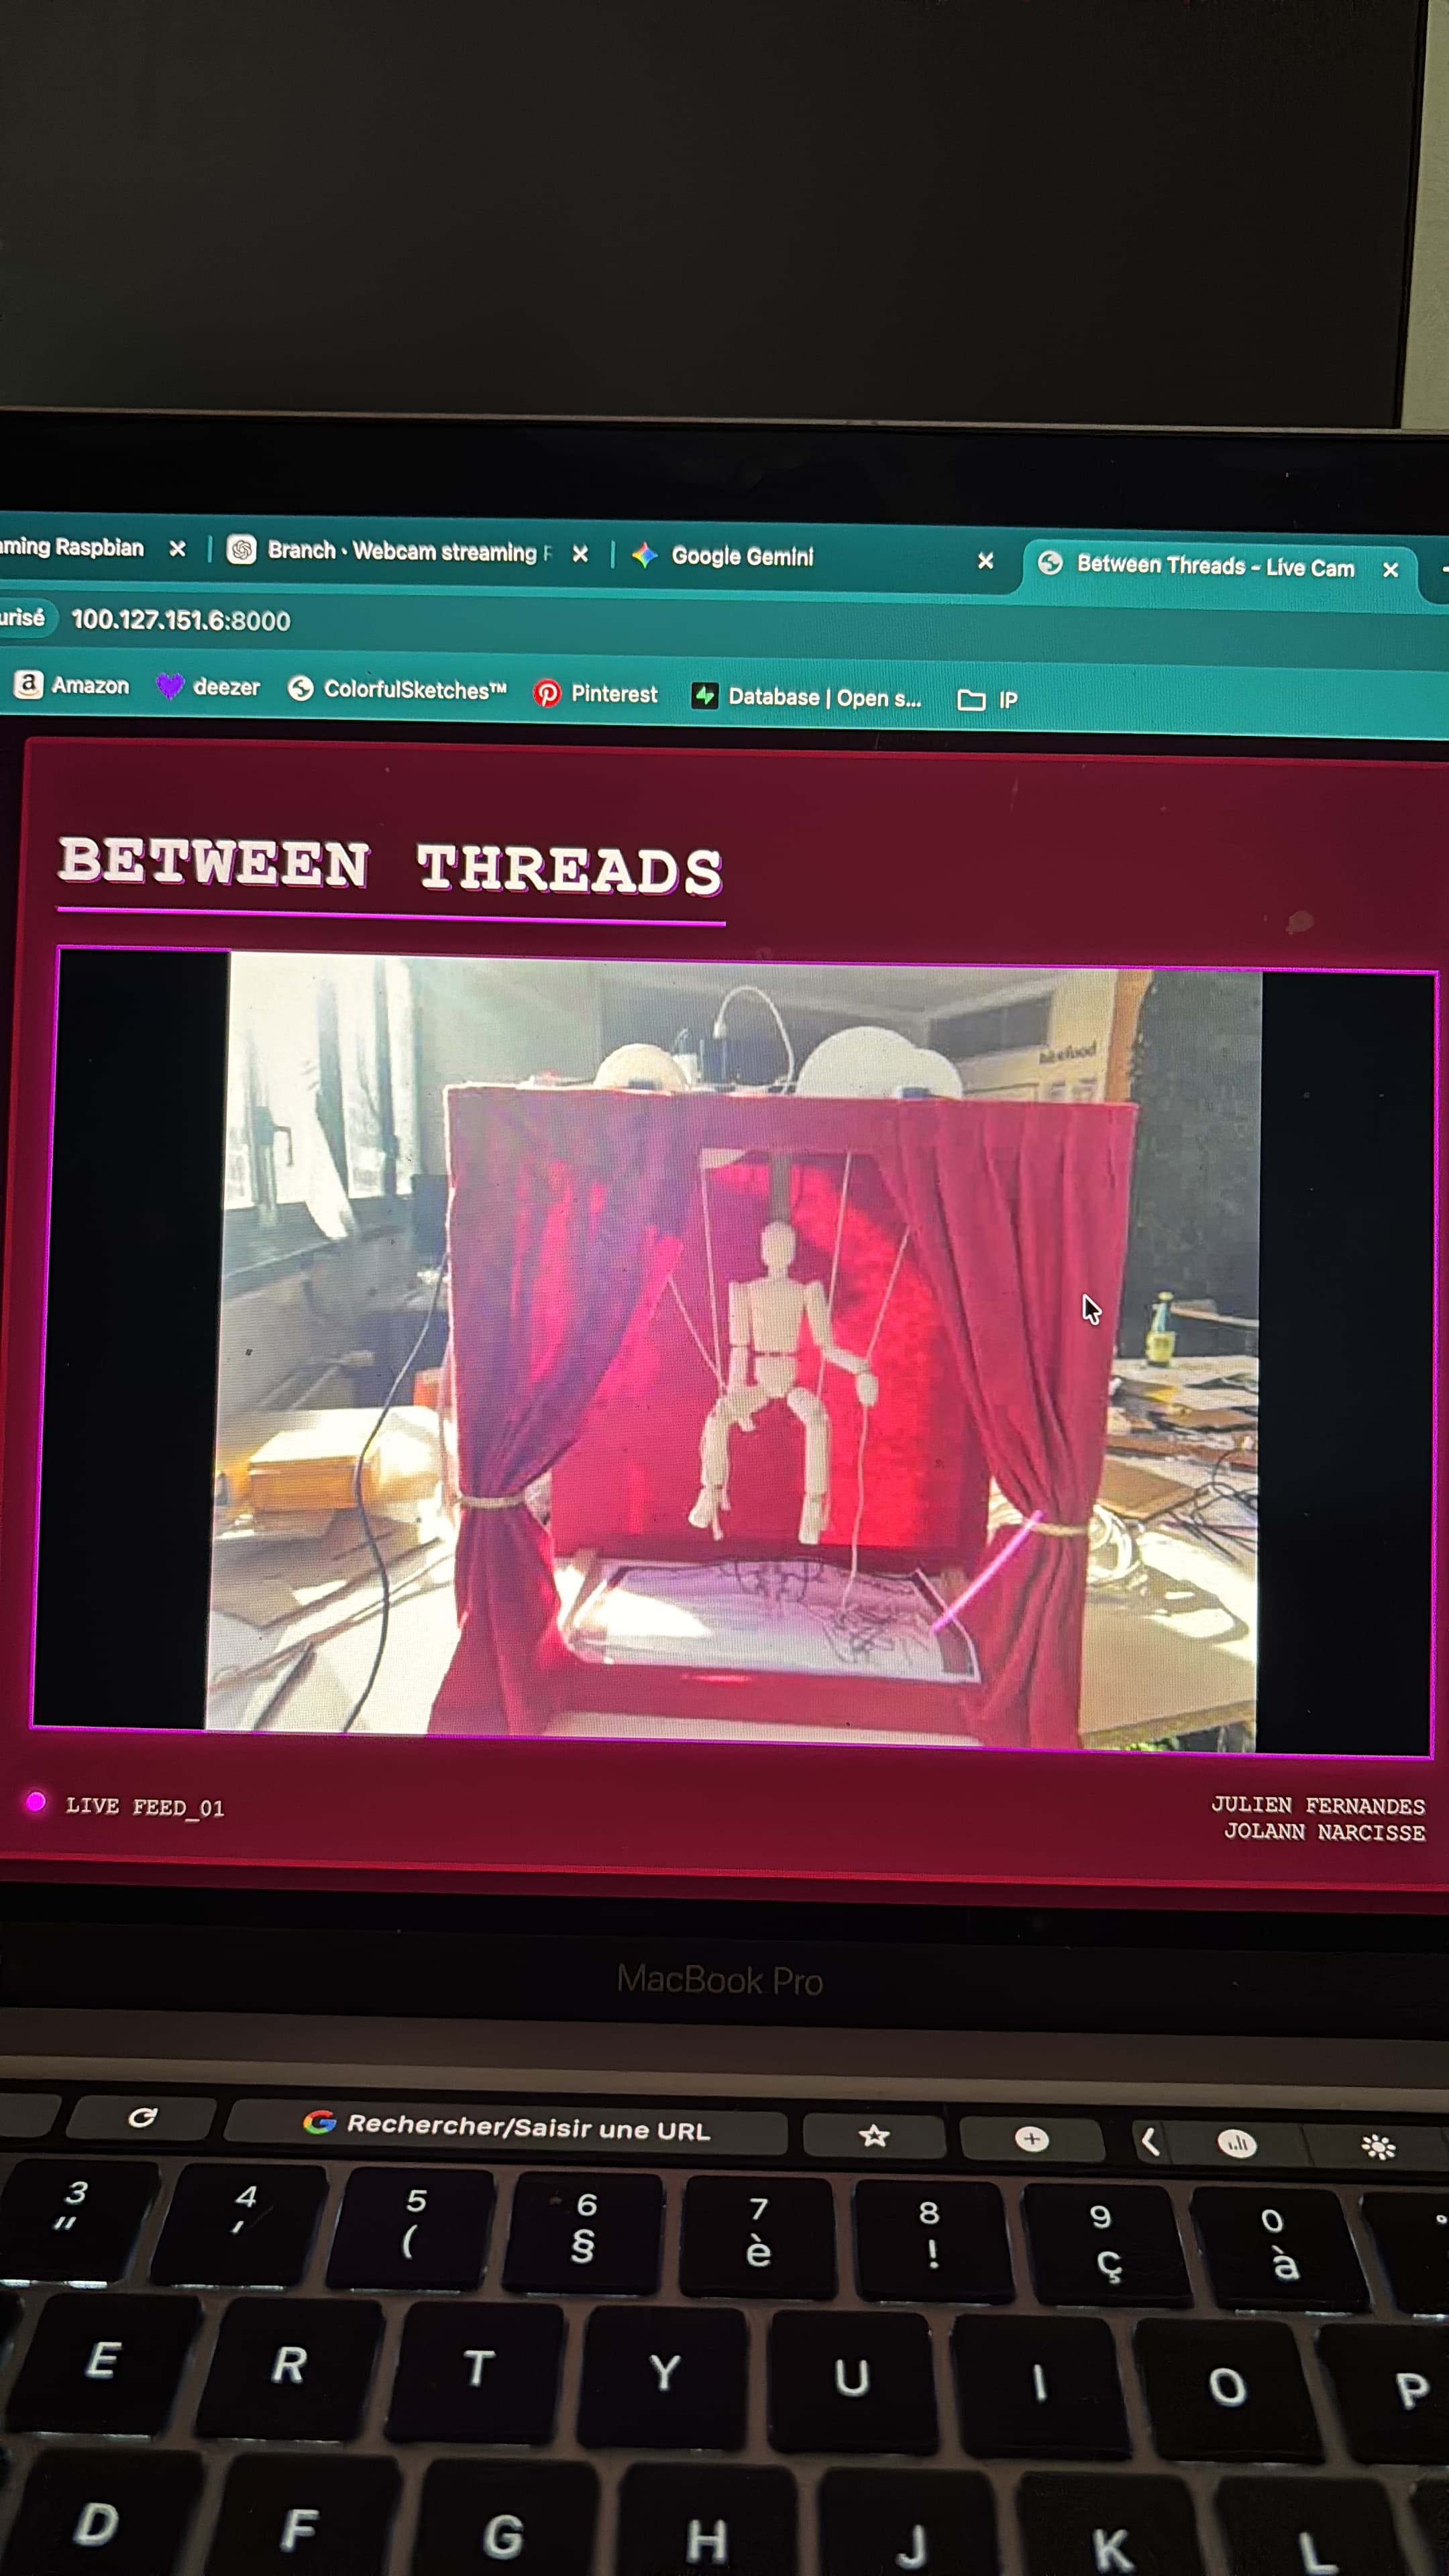
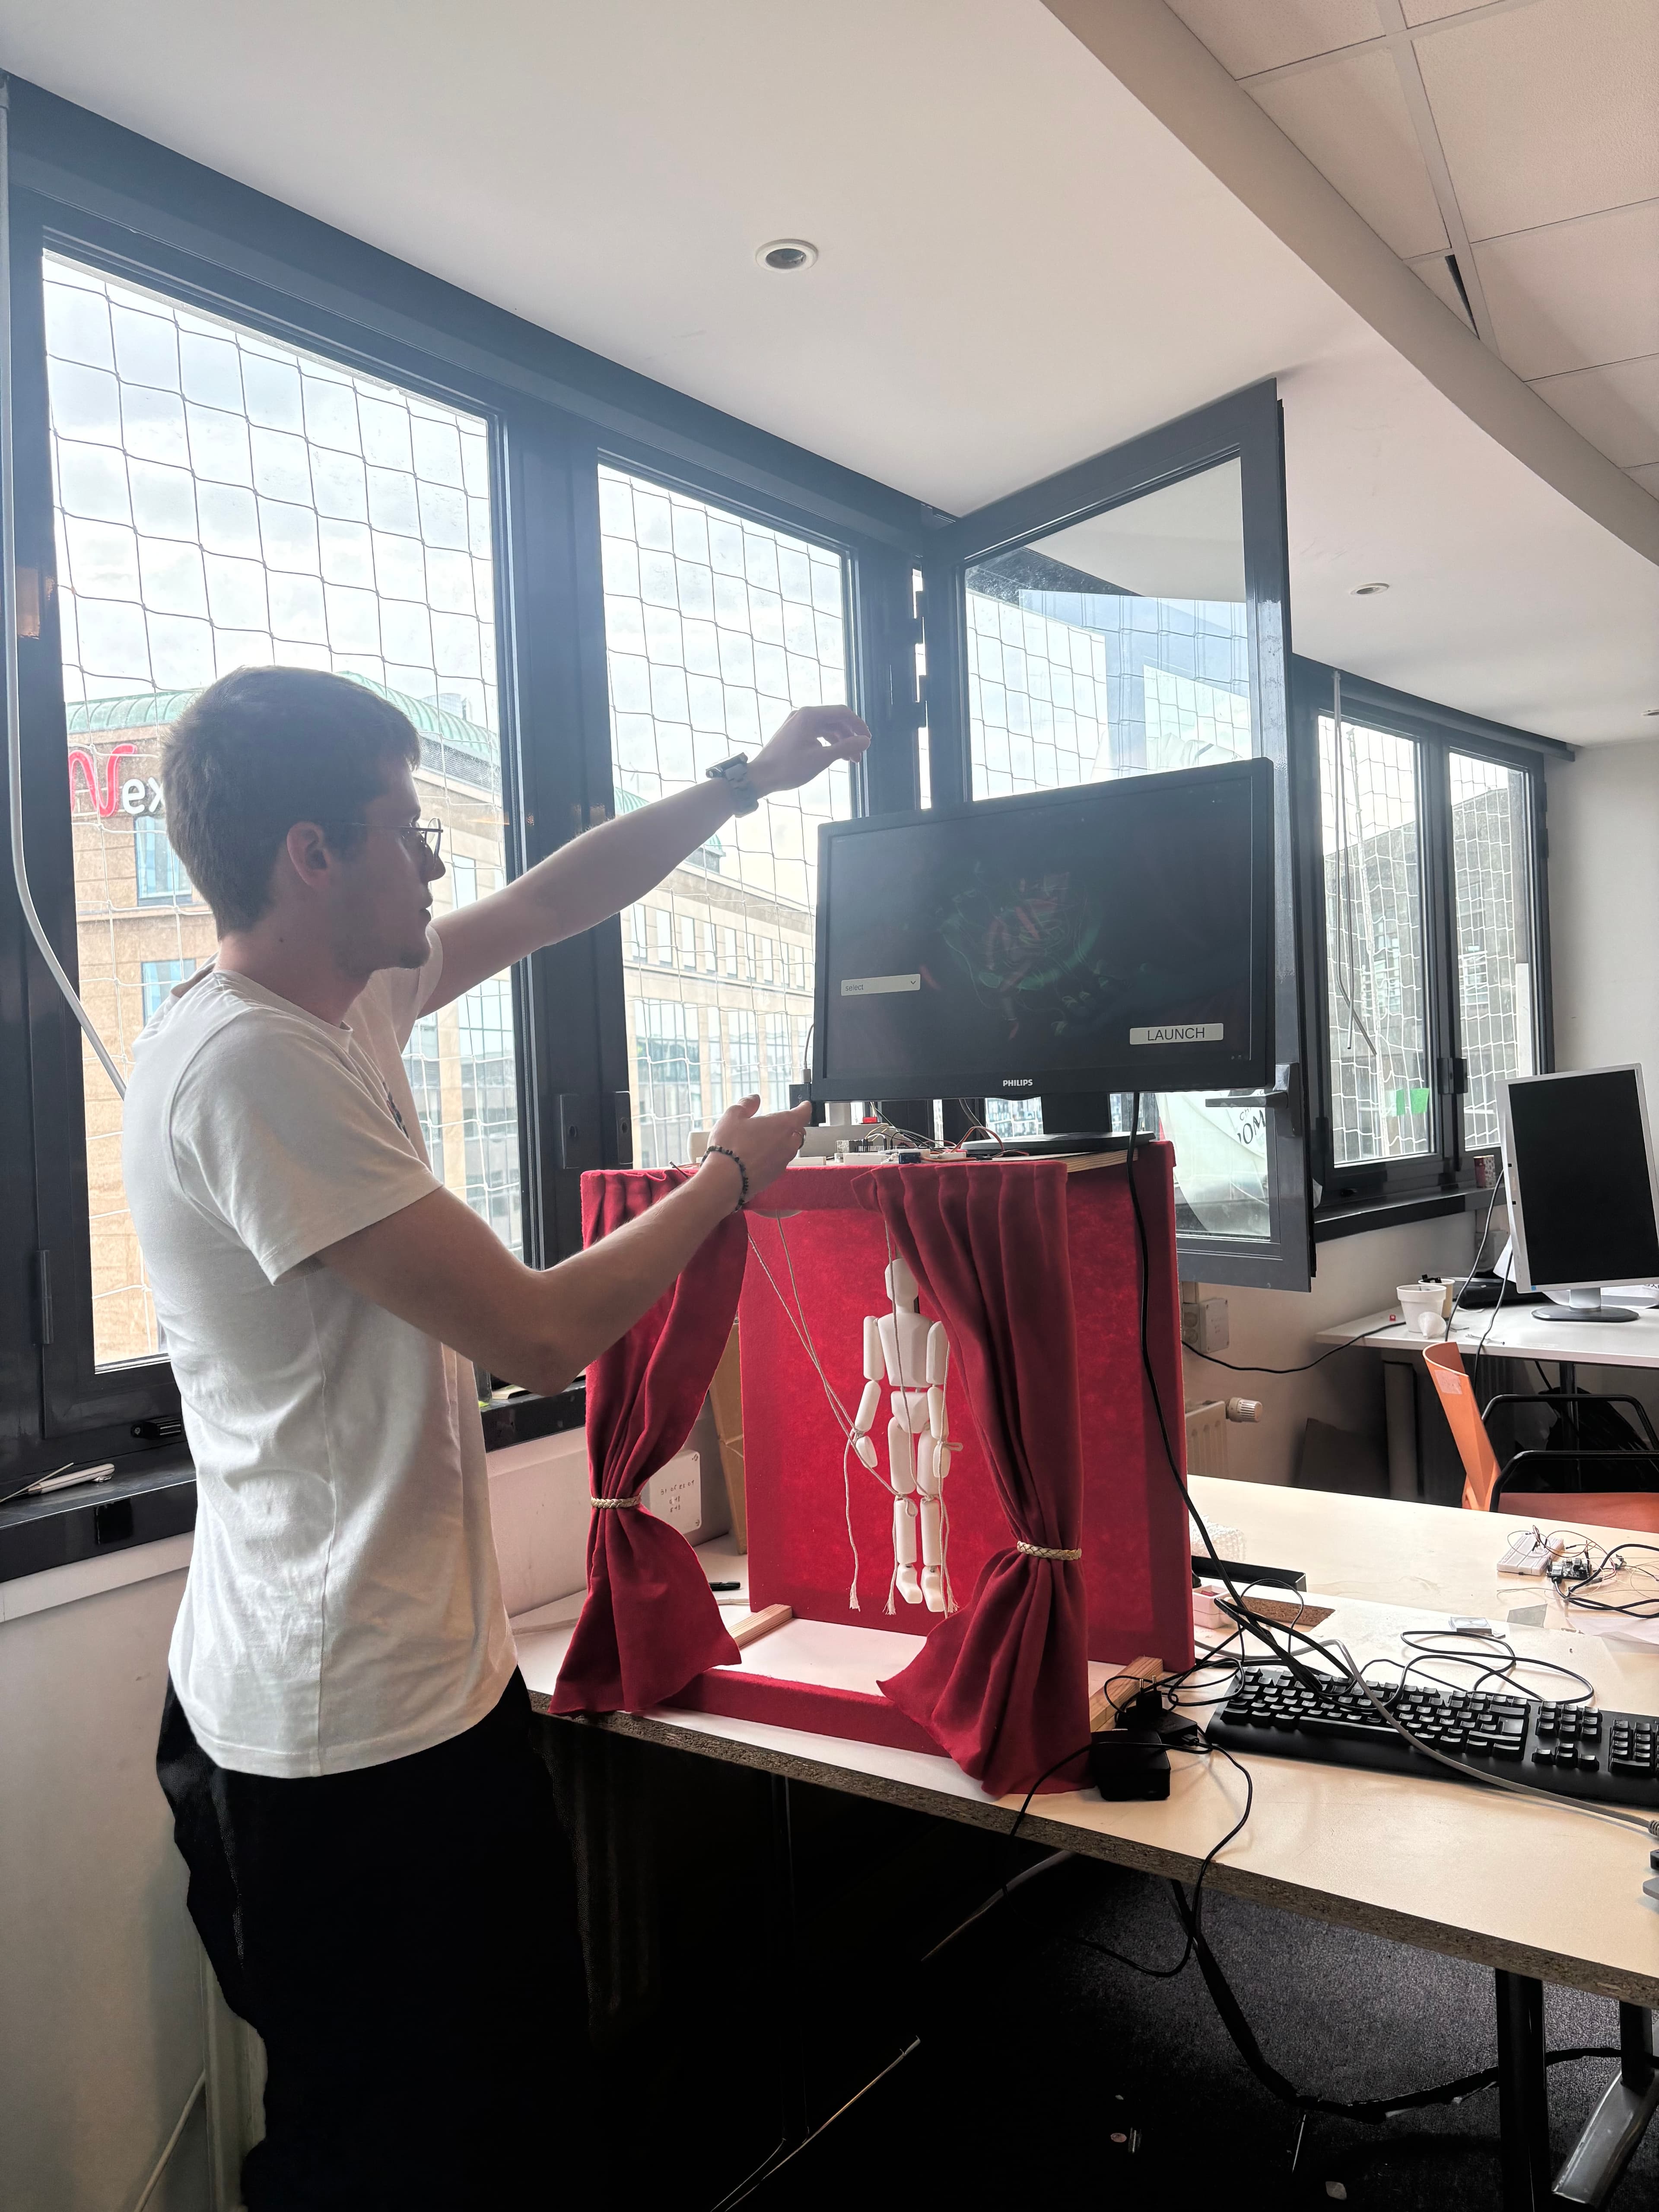
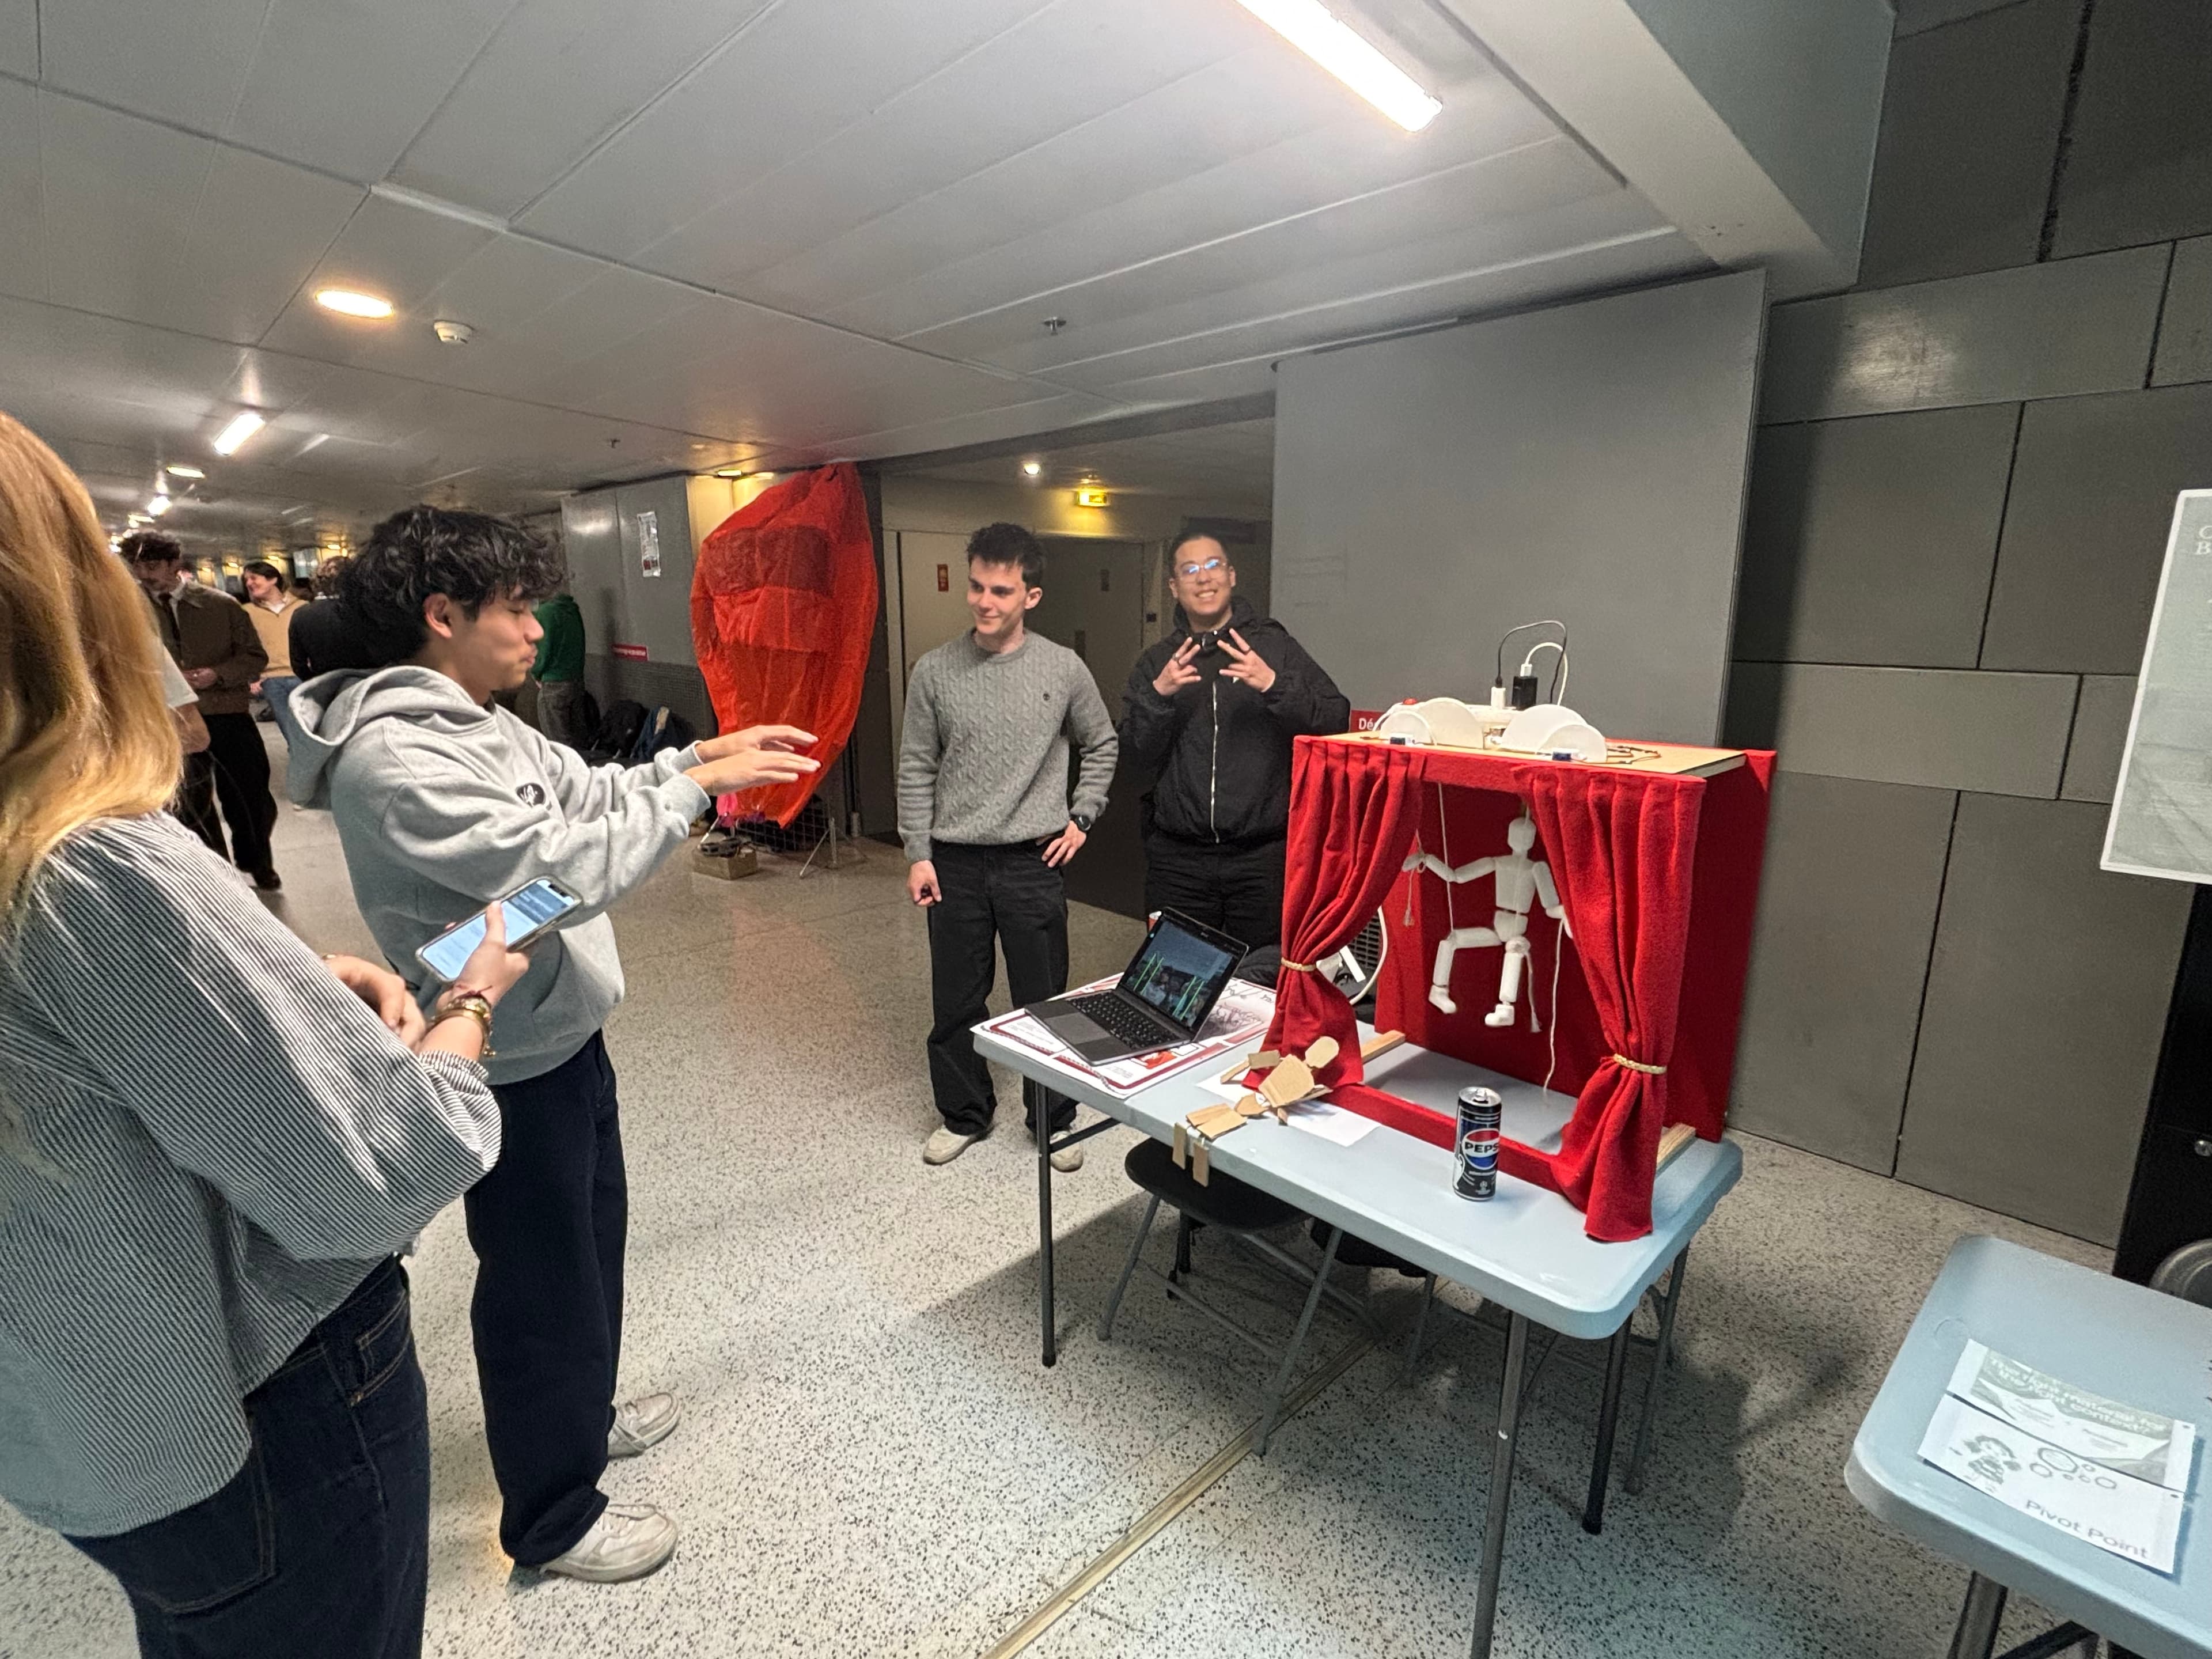
Between Threads explores a modern puppet system in which hand movements become a physical control interface. A hand-tracking pipeline follows the fingers and sends their movements to servo motors, turning gestures captured by a camera into live mechanical motion.
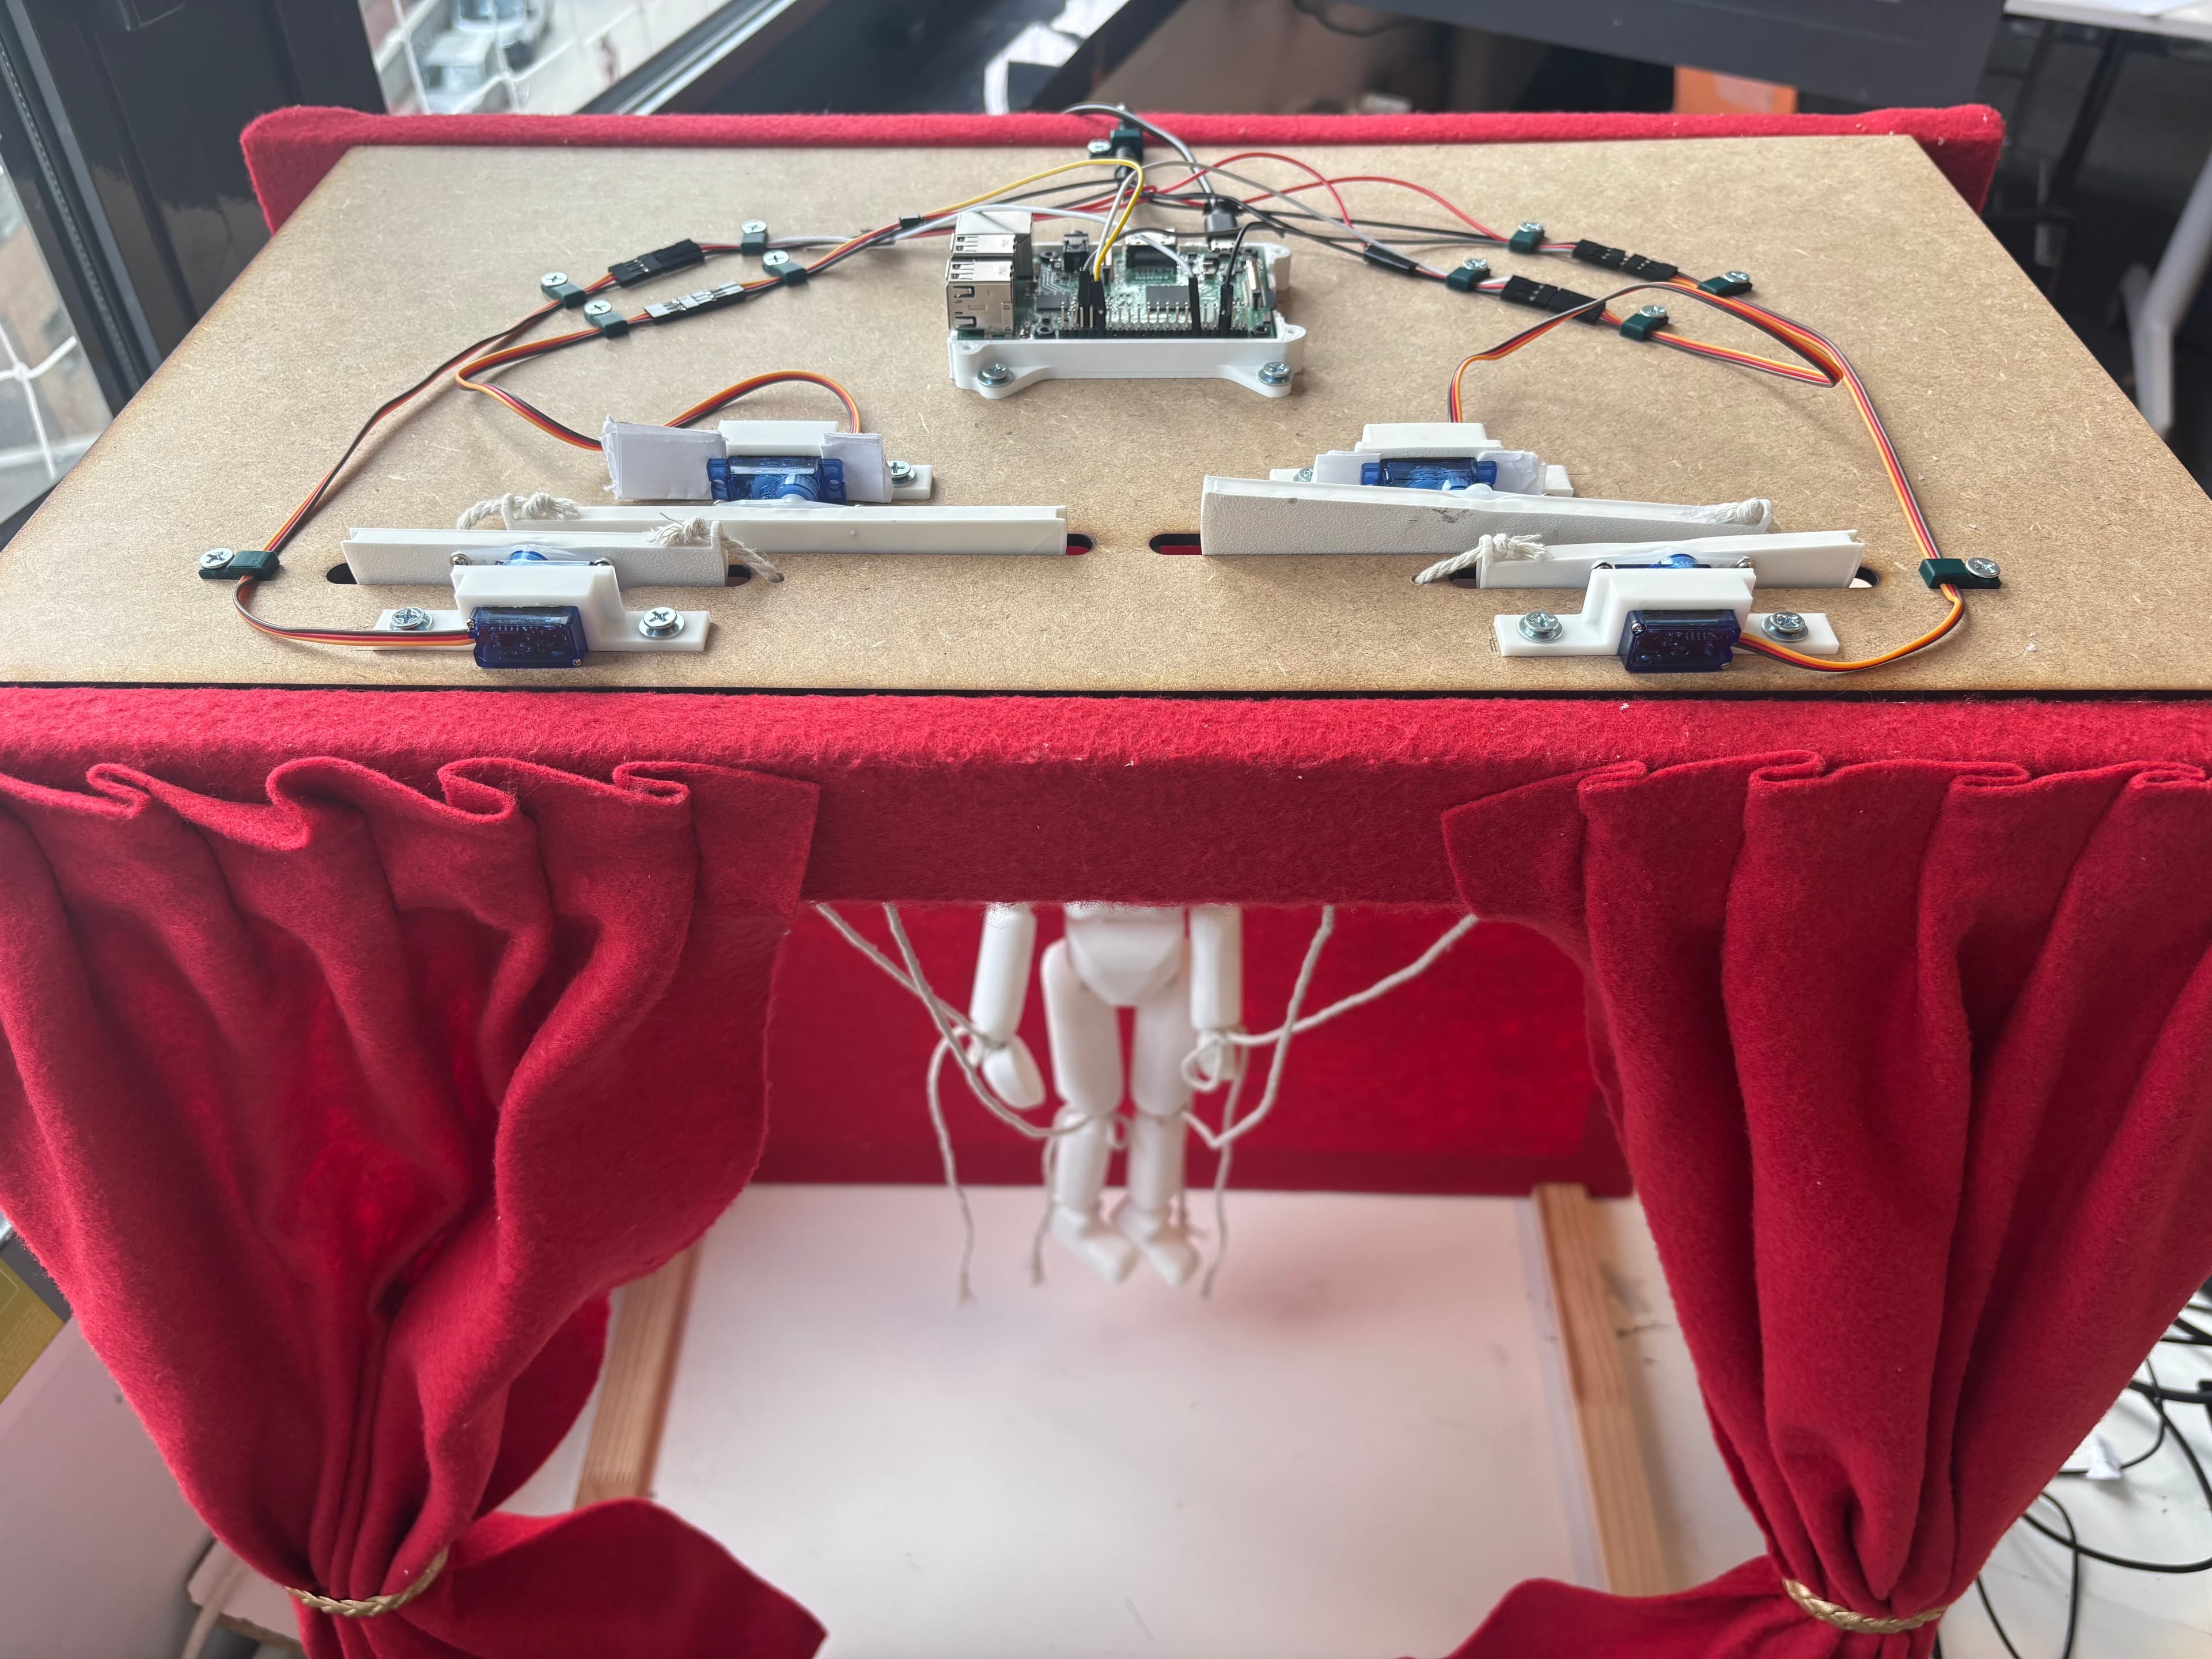
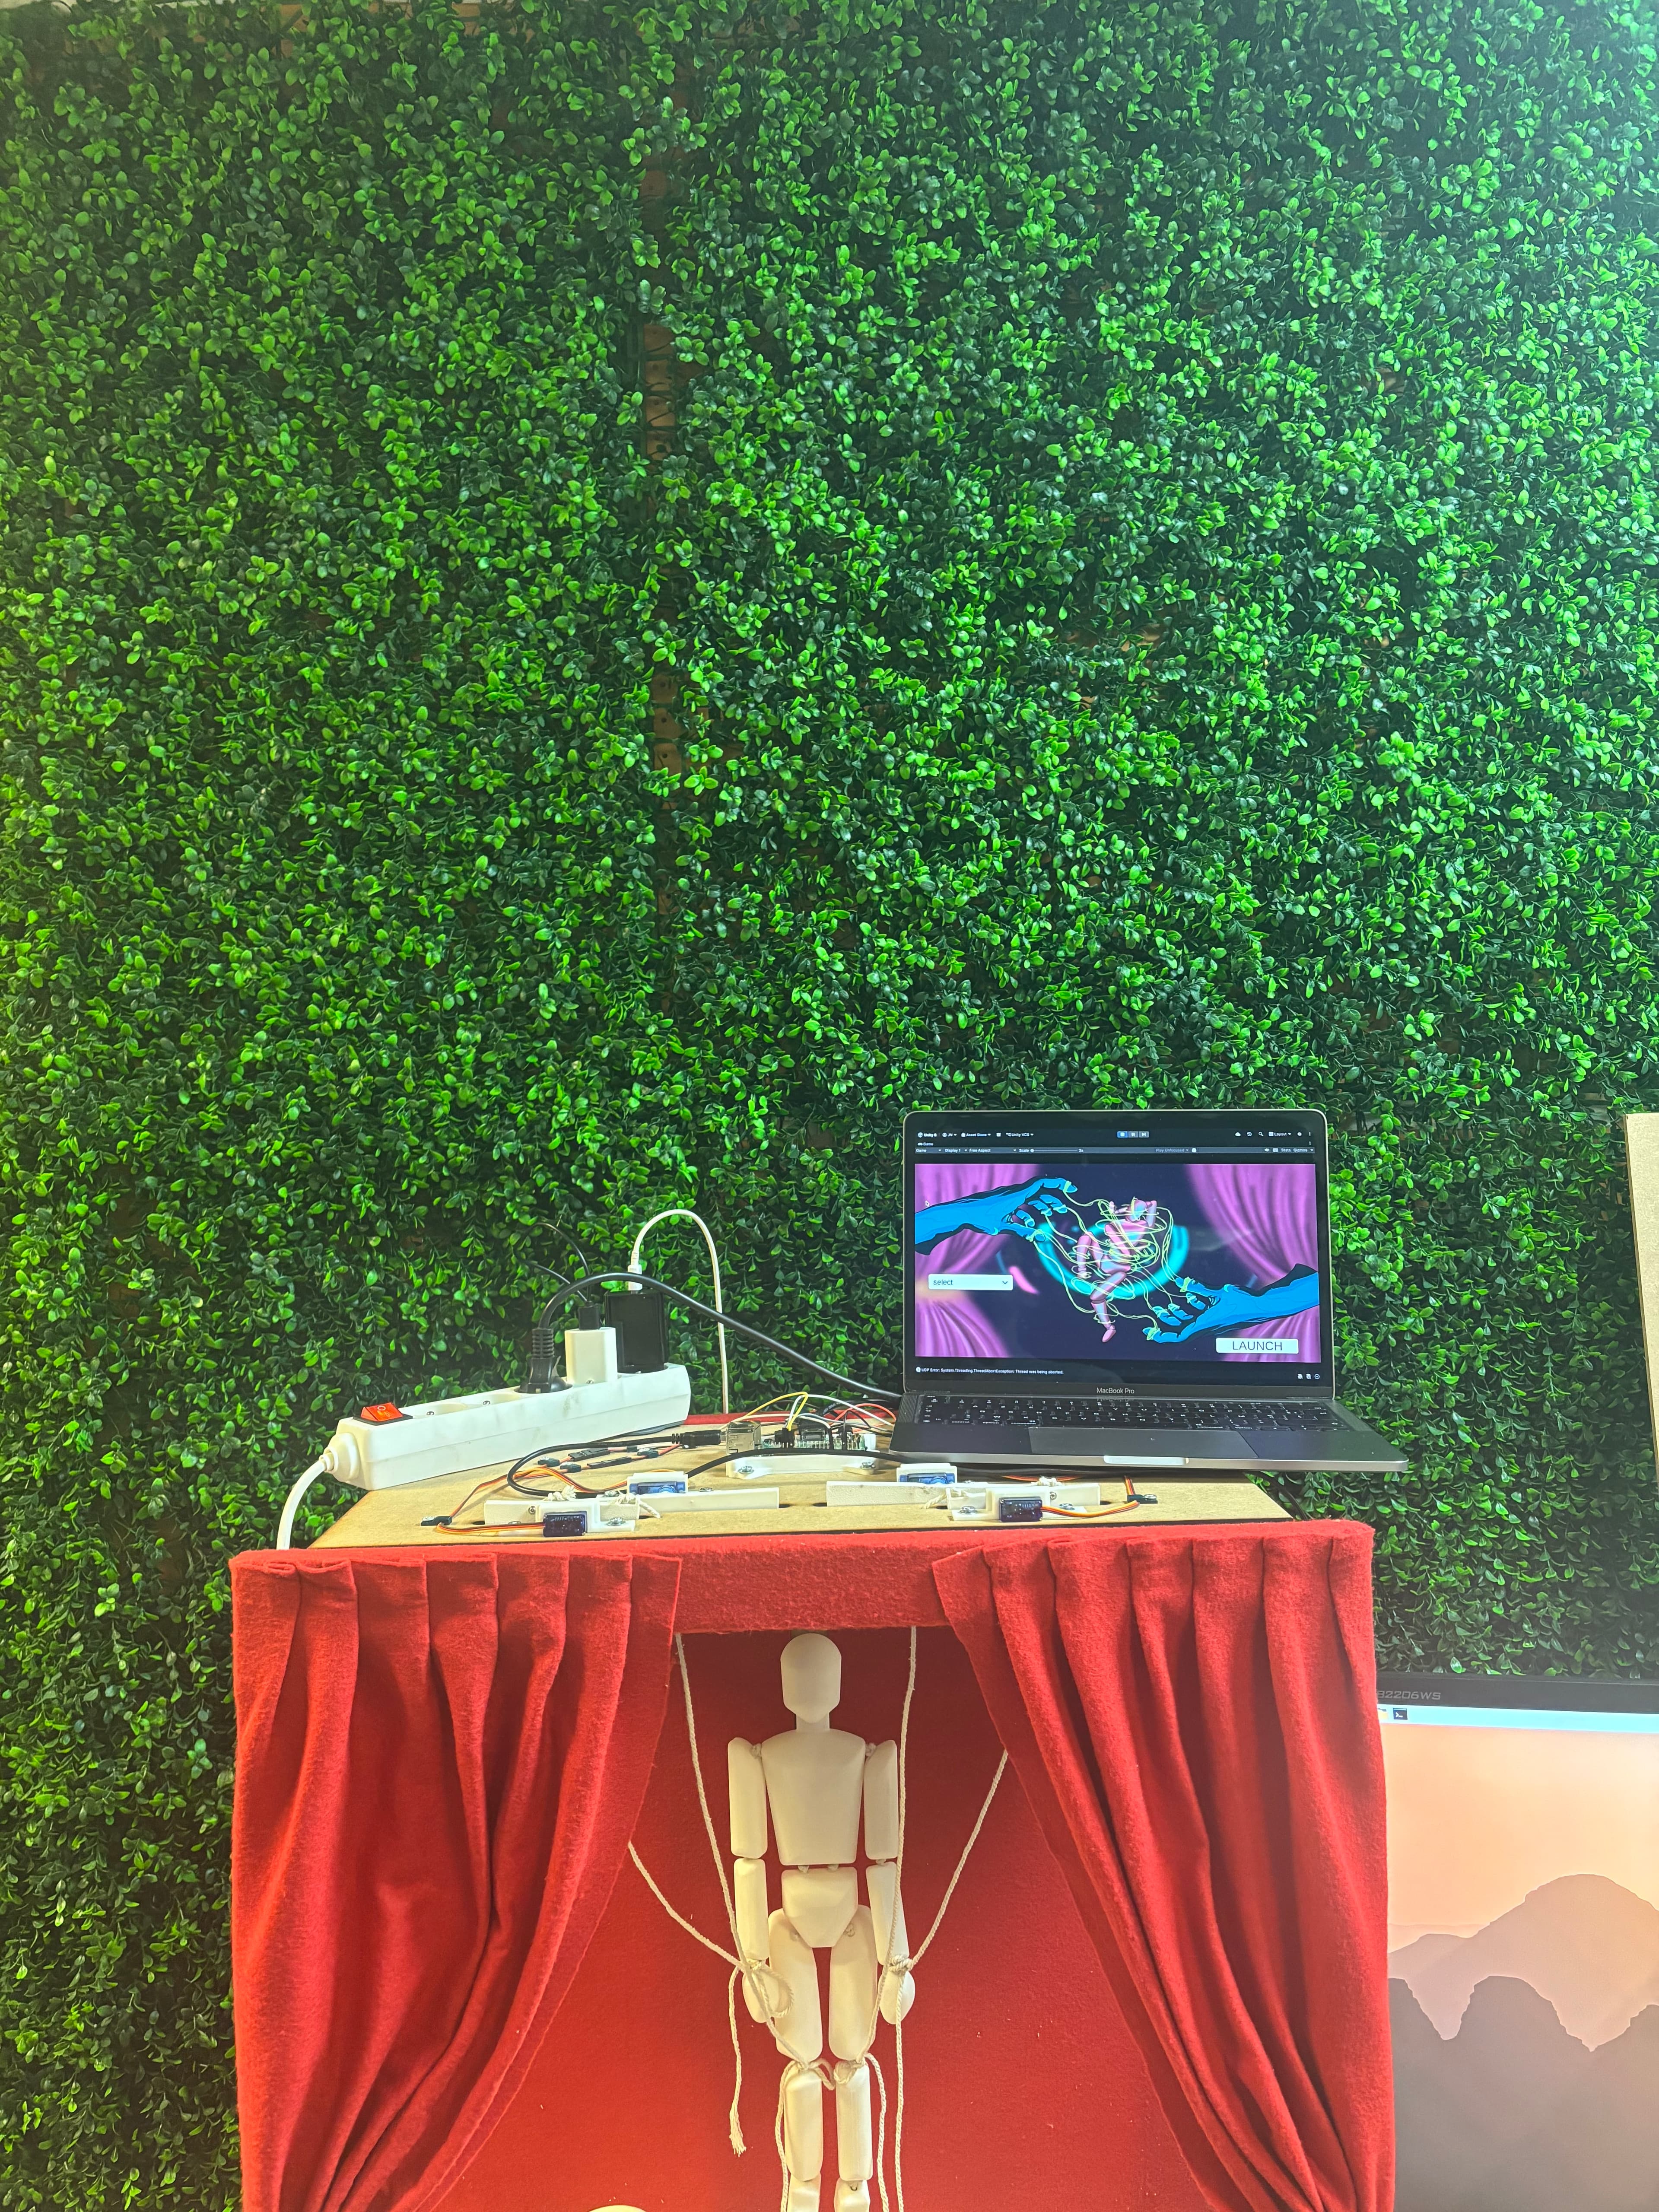
The system is split into independent services: hand recognition, motor control on a Raspberry Pi, a web dashboard, a Unity interface and live video streaming. UDP and WebSockets connect the modules, while the hardware repository brings together the wiring and printed parts. The project connects computer vision, real-time communication and physical fabrication in one interactive installation.